Autonomous Drone Mission Planning
Sim to flight missions planned and validated in Gazebo before they fly.
- Client
- Confidential
- Year
- 2024
- Category
- Robotics
- Role
- Design + Build
- Timeline
- 6–8 weeks
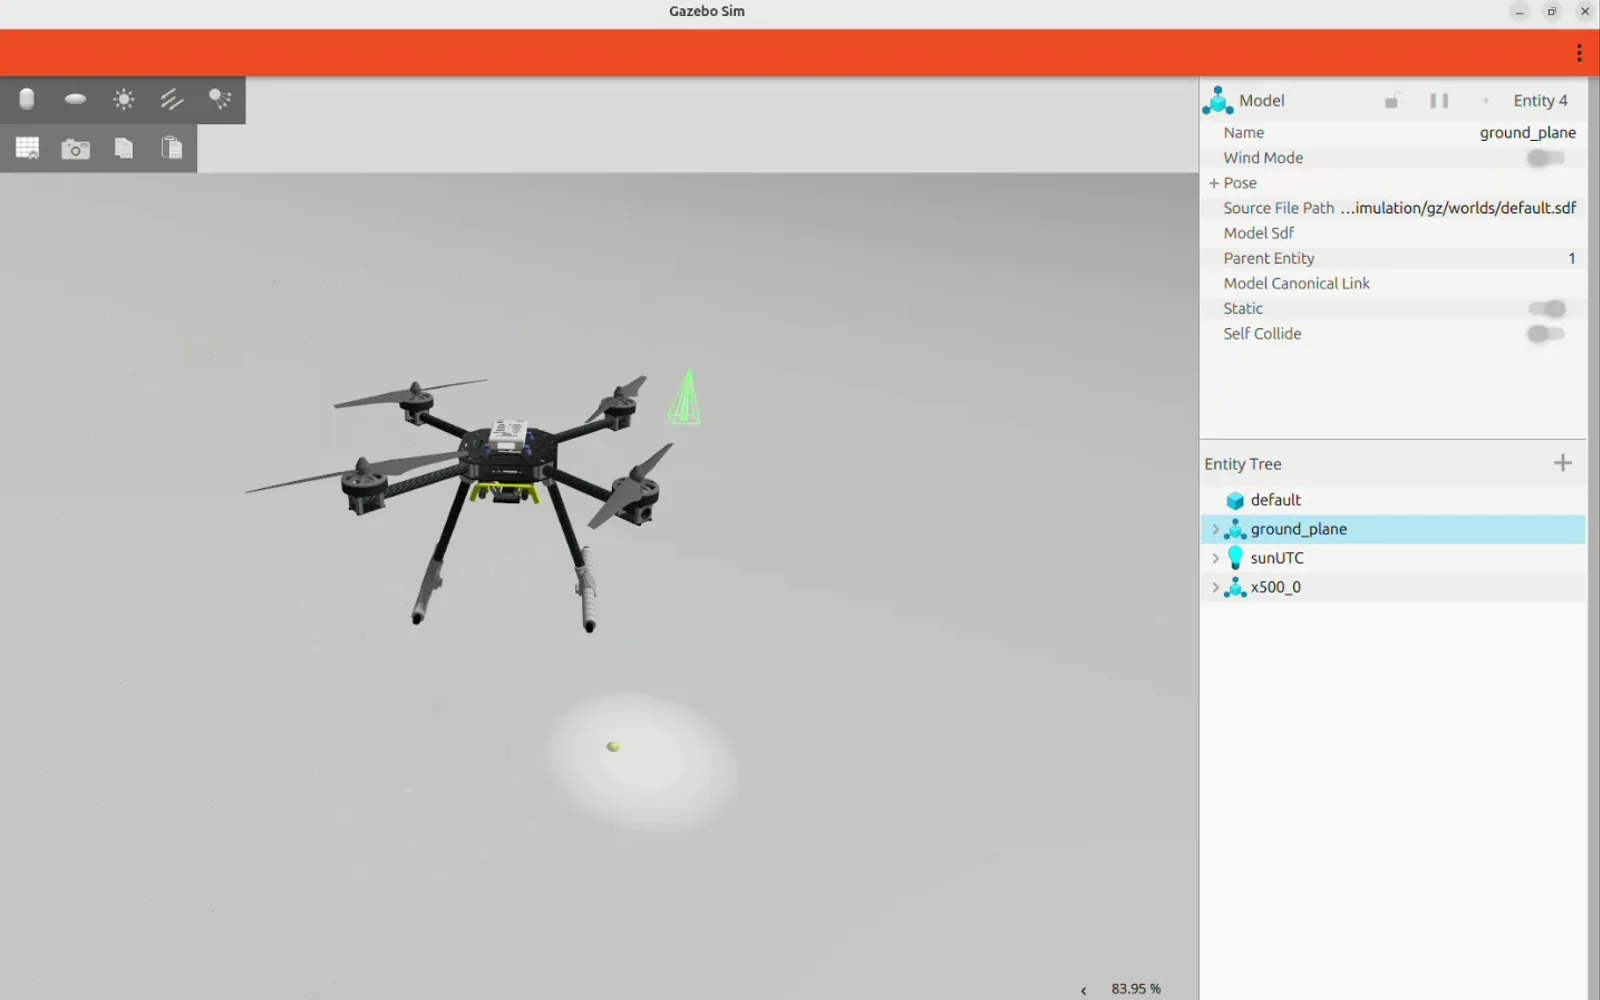
Sim to flight missions planned and validated in Gazebo before they fly.
Testing autonomous flight behaviour on real hardware is slow and risky. A crash costs a week.
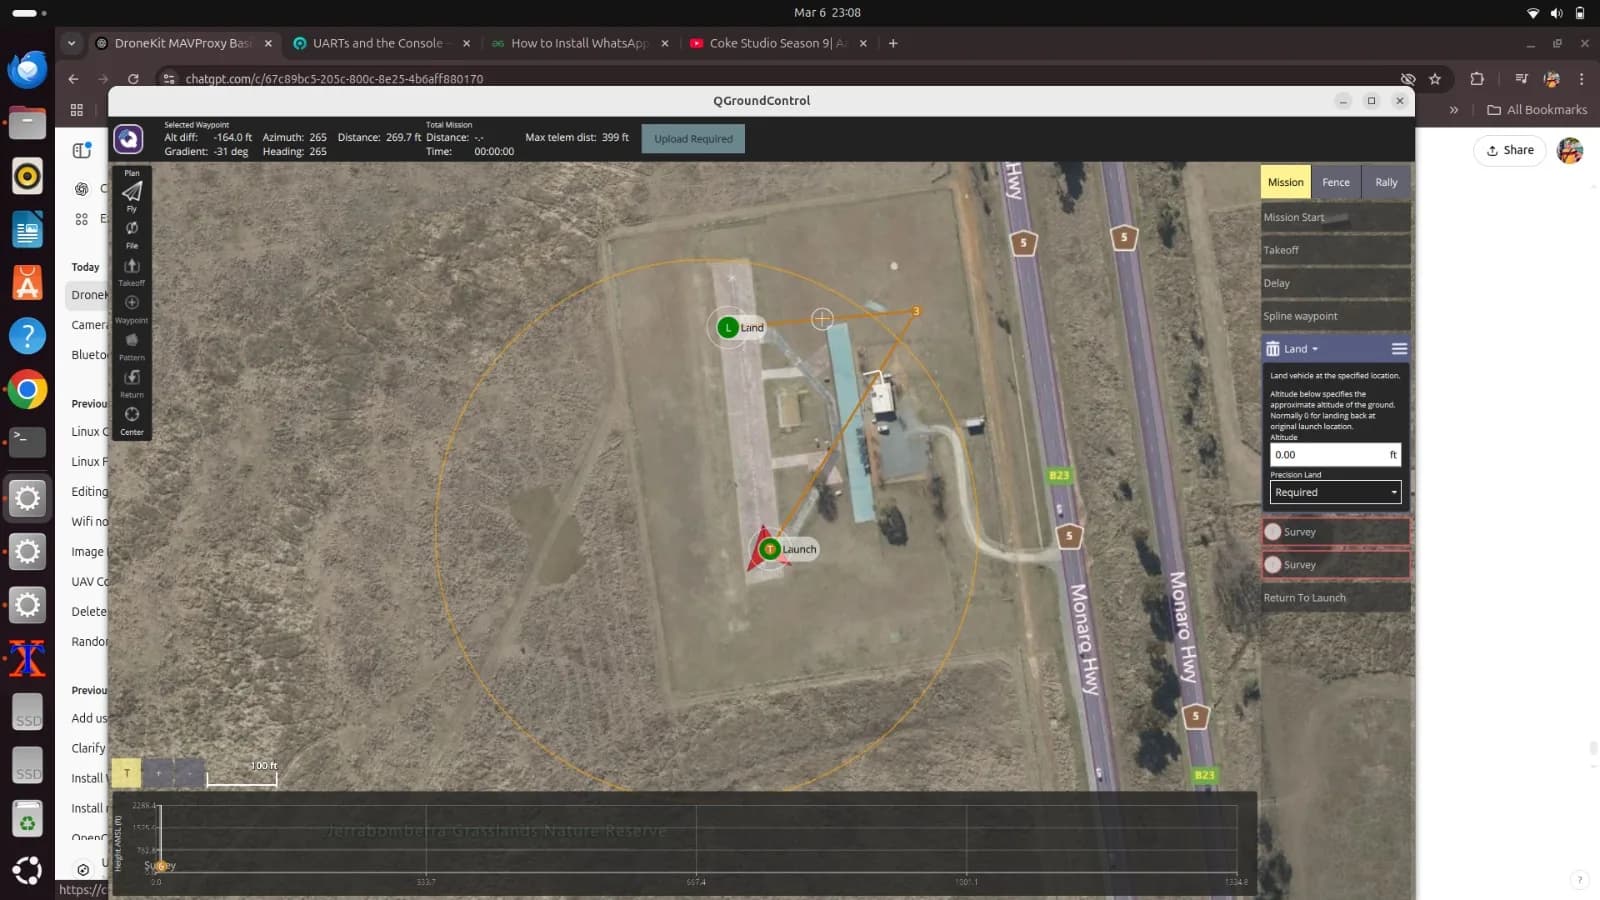
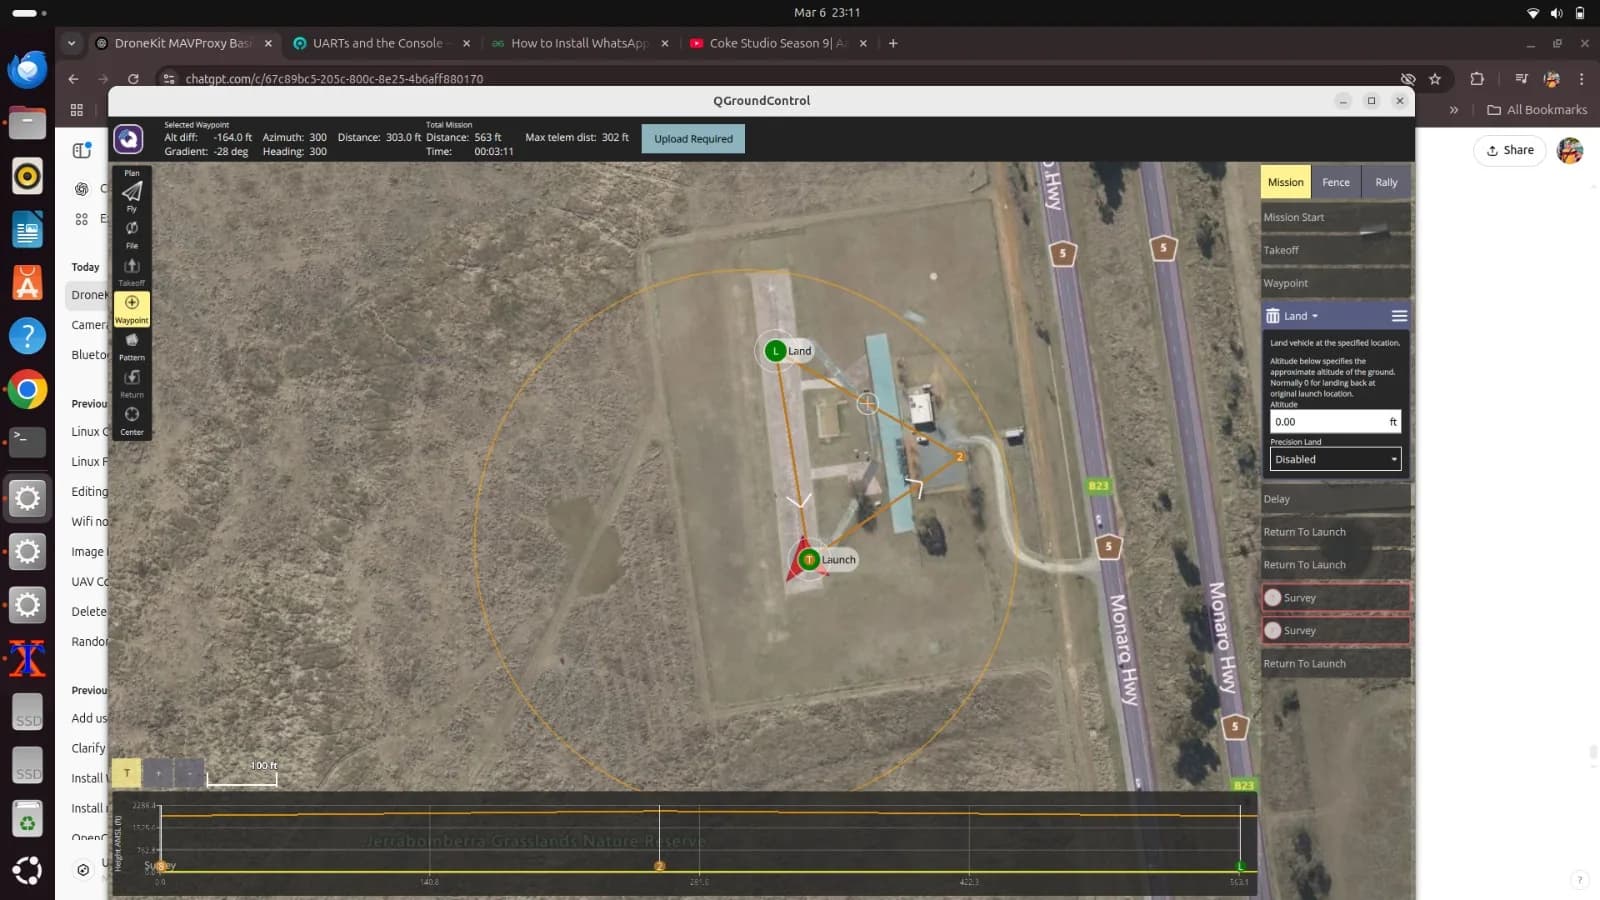
A Gazebo simulation of the quad and its environment lets missions, including waypoints, altitudes and behaviours, be built and validated in software first, then executed on the real airframe through a QGroundControl link. The loop is: plan, simulate, adjust, fly.
Mission behaviour is proven in sim before it ever leaves the ground, so field time is spent flying working missions, not debugging them.
Built with
We deliver what we commit.
We'll come back within 24 hours with honest feedback on scope, timeline and cost, whether or not we turn out to be the right fit.